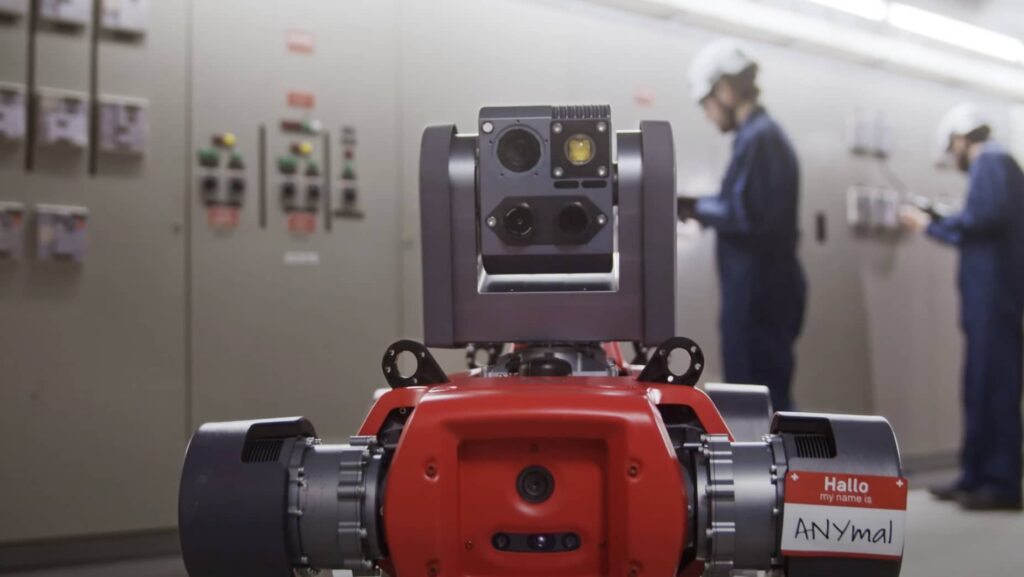
Wheel-legged platforms combine rolling movement with articulated leg mechanisms. The interesting question for a pilot is when that combination helps the assigned route, and which transitions require special validation.
Practical guidance from Desert Horizon. Product examples illustrate a category; capabilities depend on the exact supplied configuration.
Map the surface changes
Identify smooth travel segments, rough sections, steps and obstacles. Ask the supplier to explain the supported operating modes for the exact model. Avoid assuming that a dramatic movement in a video is a routine production behaviour available under every load and software configuration. The demonstration should reproduce your relevant transition.
Test the transition, not only each surface
A machine may handle two surfaces individually but still encounter difficulty between them. Include approach angle, traction, clearance and the carried payload in the trial. Record where operator input is required. This makes the result more useful than an overall statement that the robot can travel “outdoors”.
Compare the complete mission
Measure task completion, intervention frequency and the observations obtained at the destination. Include battery and recovery arrangements. A hybrid platform should be chosen because its mobility supports a defined mission, not because it combines two attractive technologies. Keep the selection tied to route evidence and the supported configuration.
Three points to take into your project
- Ask which modes are supplied.
- Test transitions under load.
- Record operator interventions.