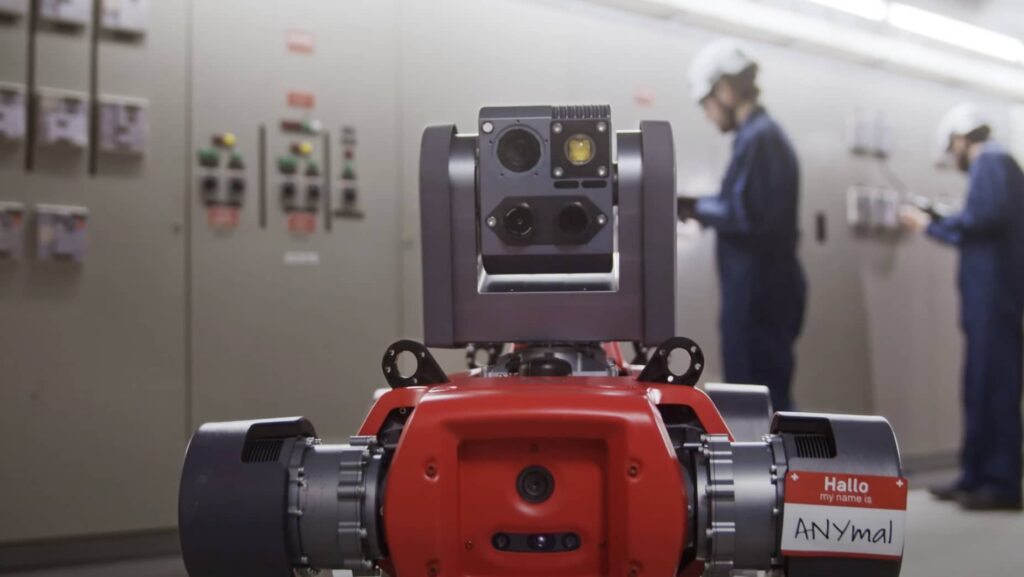
LiDAR provides spatial observations that can support a robot’s perception system. A sensor purchase is not the same as buying a complete navigation solution; mounting, software and the operating environment still determine the result.
Practical guidance from Desert Horizon. Product examples illustrate a category; capabilities depend on the exact supplied configuration.
Define the perception question
Decide whether the project needs a map, obstacle observations, localisation or research data. These objectives may require different processing and interfaces. A sensor can provide suitable raw information while the project still lacks the software needed to turn it into a navigation decision. Make the deliverable explicit before comparing devices.
Plan mounting and calibration
Check the field of view, blind areas, vibration and objects that may obstruct the sensor. Review power, communication and the path of cables. Test with the robot’s actual movement rather than only a stationary bench setup. Keep a record of calibration and mounting changes so that software results can be interpreted consistently.
Validate difficult observations
Include the materials, lighting and geometry the robot will encounter. Document missed or uncertain observations and decide how the system responds. A general-purpose perception sensor should not be assumed to provide a certified personnel-safety function. Navigation performance and application safety are related engineering topics, but they are not interchangeable claims.
Three points to take into your project
- Define the required perception output.
- Test on the moving platform.
- Document blind areas and uncertain observations.