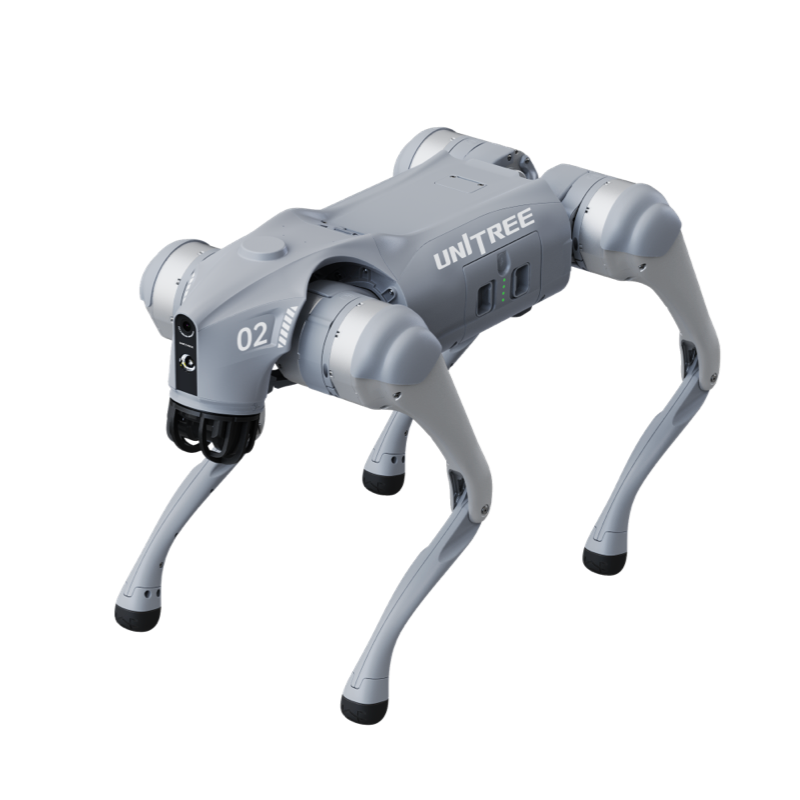
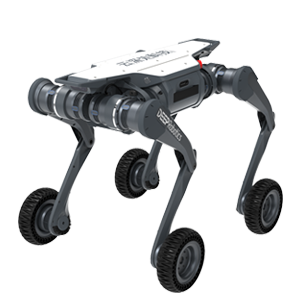
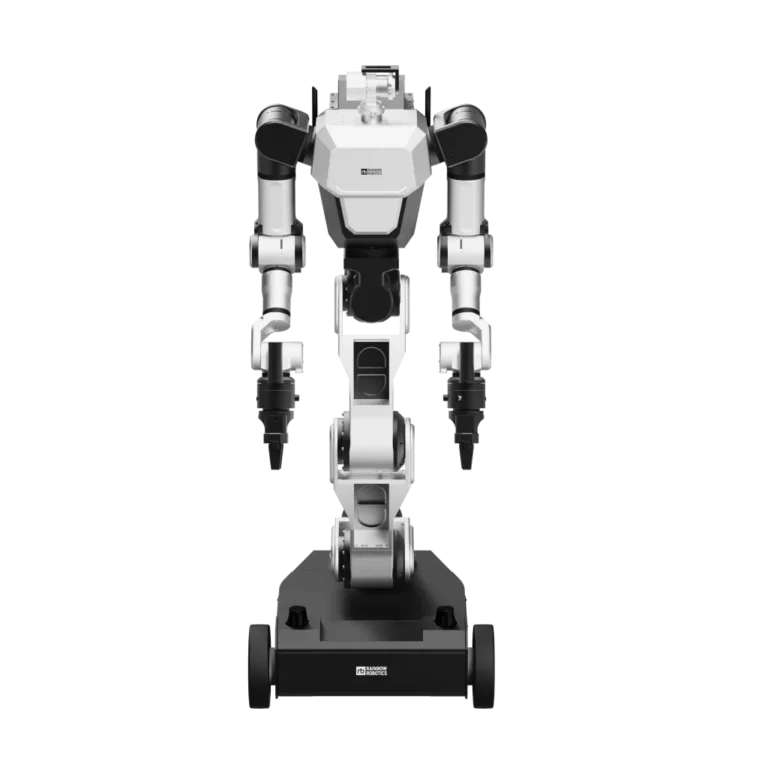
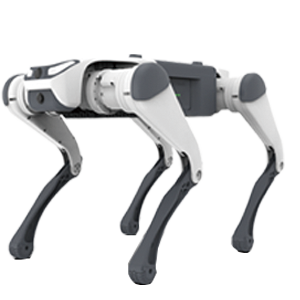
The best mobility architecture depends on the route and task. A wheeled base, a quadruped and a wheel-legged machine solve different access problems, and each must be evaluated with the intended payload.
Wheel-legged platforms combine rolling movement with articulated leg mechanisms. The interesting question for a pilot is when that combination helps the assigned route, and which transitions require special validation.
LiDAR provides spatial observations that can support a robot’s perception system. A sensor purchase is not the same as buying a complete navigation solution; mounting, software and the operating environment still determine the result.
Robotics videos can show similar-looking behaviour produced in very different ways. Understanding who makes each decision helps buyers judge what work remains after the equipment arrives.
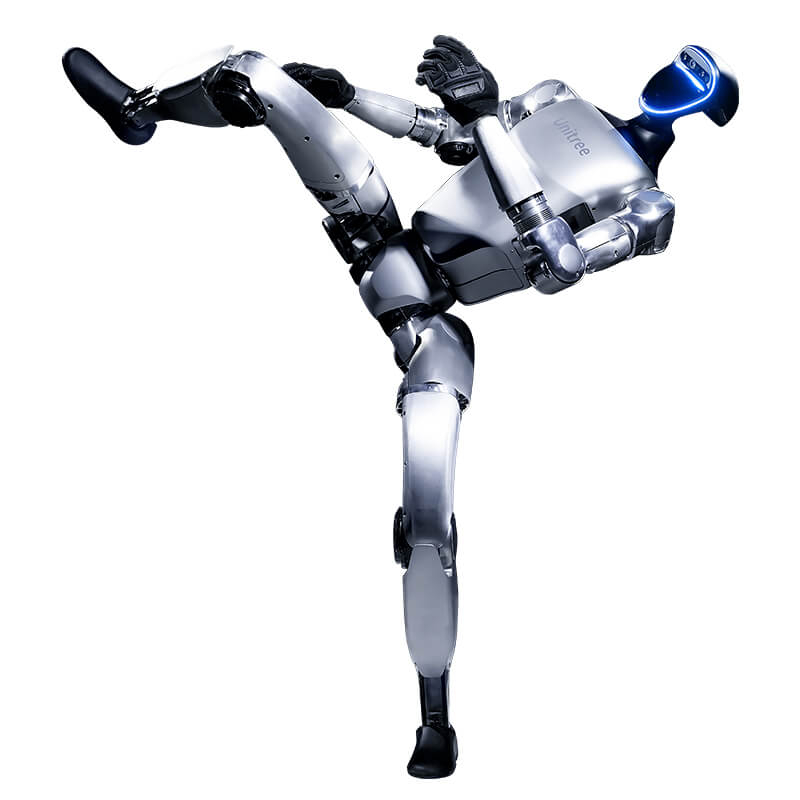
Embodied AI research connects perception and decision-making with physical action. Hardware should be chosen around the experiment’s interfaces, scale and repeatability rather than the ambition to buy the most visually impressive robot.
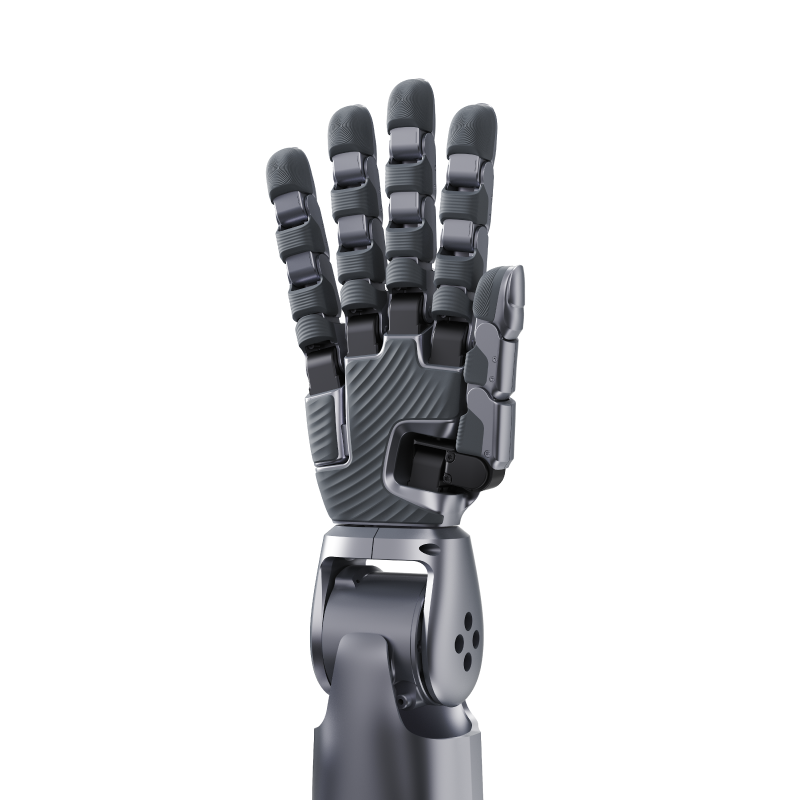
A dexterous hand can support complex manipulation research, while a simpler gripper may be easier to integrate for a defined handling task. The object and required contact behaviour should drive the choice.
A motor or integrated joint is one part of a mechanism. Its suitability depends on the complete load case, electrical system, controller and operating cycle, not only a peak torque value.
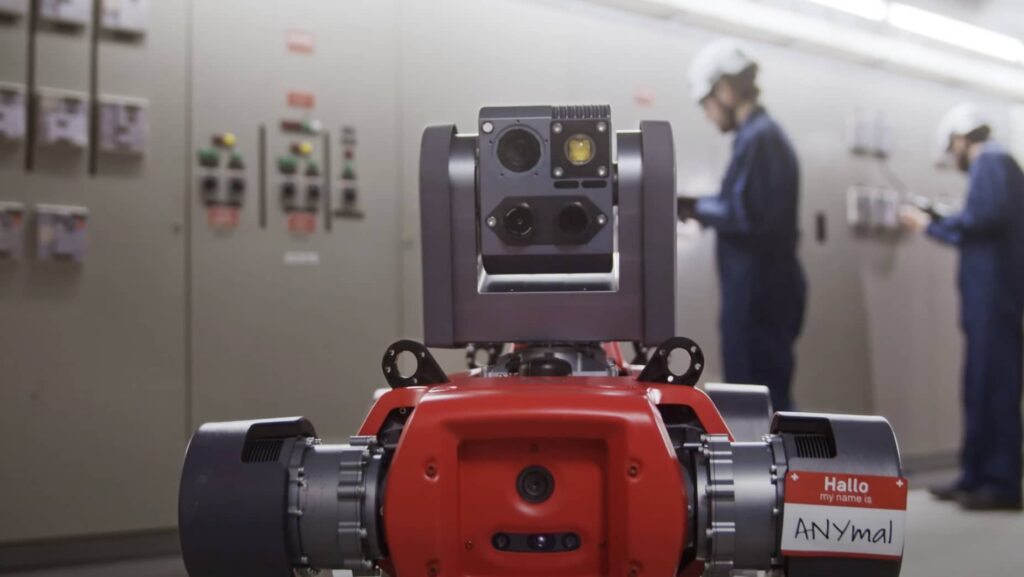
Inspection sensors answer different questions. A camera view, a thermal image and an acoustic recording should be selected for the asset condition the team needs to understand, rather than collected simply because the robot can carry them.
A runtime figure is useful only when its test conditions resemble the intended work. Payload, motion, sensing and environmental conditions influence how a robot’s energy budget fits a mission.
Development access is a purchasing requirement, not a detail to discover after delivery. Different versions of a robot can expose different interfaces, software packages and support arrangements.
Guides are written for this journal. Deployment stories distinguish supplier-reported accounts from our practical interpretation. Catalogue images illustrate robot models; they are not photographs of the described customer deployments.
With your permission, Google Analytics and Google Ads cookies help us understand traffic sources, product interest and completed purchases. We do not send your name, email, phone number or enquiry text to Analytics. Essential shop functions work without optional cookies. Privacy policy